Forward to the Future: A Deep Learning-based Approach to Mitigate Control Transmission Delay of Teleoperated Driving in Unstructured Environments
High-Reliability Teleoperation Assistance based on Deep Learning and Human-Computer Interaction
Deep learning-based prediction of future control inputs to compensate for transmission delay in teleoperated driving.
About this project
Research project in 2024; published in IET Electronics Letters in 2025.
- Hyeonggeun Yun
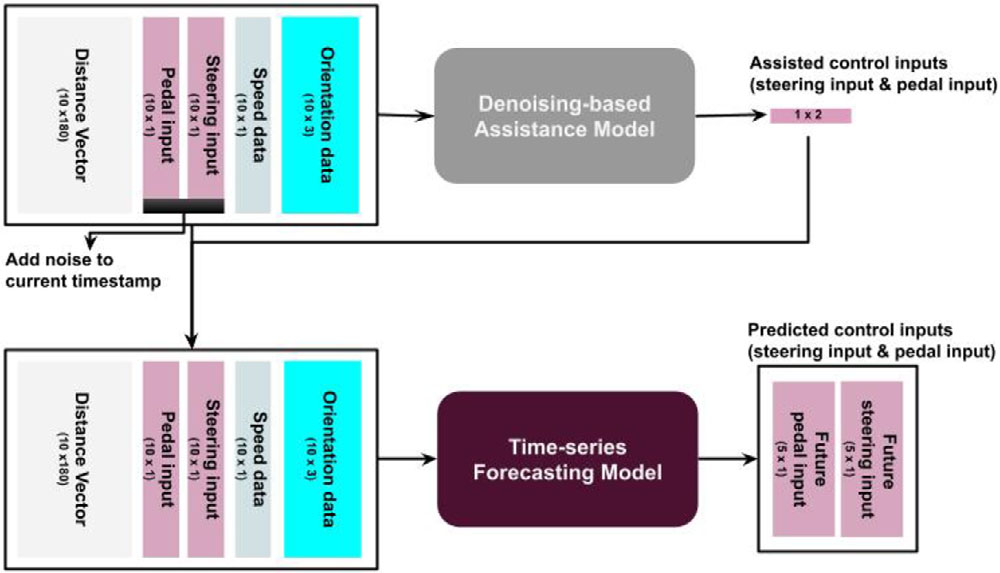
Teleoperated driving is a leading approach for operating unmanned ground vehicles (UGVs) in unstructured environments, where driving stability is crucial. However, time delays may compromise this stability. In this letter, we propose a computational delay compensation method based on deep learning models to address the control transmission delay. Initially, we collect teleoperated driving data from simulated unstructured environments and then design a delay compensation method utilizing time-series forecasting models. This method generates future control inputs equivalent to the delayed time steps. Our evaluation demonstrates the possibility of our delay compensation method for teleoperated driving in unstructured environments.